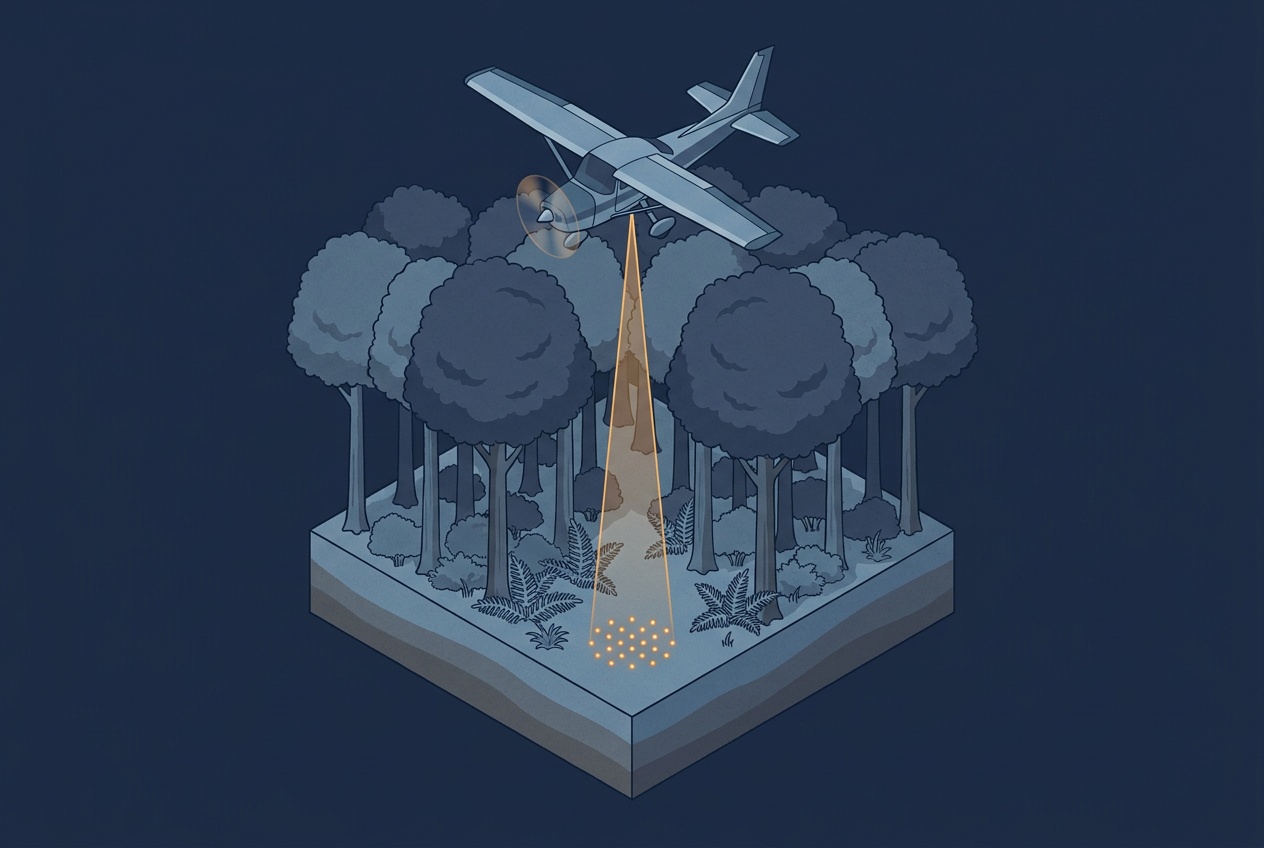
Wytham Woods is a 400-hectare deciduous forest near Oxford that has been studied by ecologists for decades. In a 2017 study, Simpson, Smith, and Wooster compared two airborne LiDAR surveys of it, one flown with leaves on the trees and one without. The terrain model from the leaf-on survey had a vertical error (RMSE) of 0.83 meters. The leaf-off survey reached 0.22 meters. That difference is not very surprising. The surprising part was where the worst errors came from. It was not the tall, dense canopy. It was low undergrowth below 3.5 meters, such as ferns and brambles, where errors exceeded one meter. Both surveys also comfortably met the point density that was considered necessary for an accurate terrain model.
This result captures a problem that practitioners run into regularly, from national programs to small drone projects. A survey can deliver the specified number of points and still produce a poor terrain model under vegetation. In this article we look at how a laser pulse finds the ground, why low vegetation is harder to see through than tall trees, which survey choices change the outcome, and what to ask about ground coverage before a terrain model is used.
How a Pulse Finds the Ground
A laser pulse is not a thin line. It leaves the sensor as a cone and reaches the vegetation as a small illuminated area, the footprint. Inside that footprint, part of the energy hits leaves and branches and is reflected back, and part of it passes through gaps in the canopy and continues downward. Each surface that sends back enough energy produces an echo, which is why a single pulse can generate several returns. If enough energy is left when the pulse reaches the ground, the last of those returns is a ground point.
This leads to a useful distinction. The pulse density on a specification sheet describes how many pulses are sent into each square meter. The ground point density describes how many of them come back from the ground and are classified as such. The second number is the first one multiplied by the share of pulses that reach the ground, and that share depends on the vegetation, not on the sensor alone. In an open field it is close to one. Under a dense evergreen canopy in summer it can be a small fraction.
The share is also not evenly spread. Gaps in the canopy are clustered, so ground points tend to arrive in patches with empty areas between them. A project can have a respectable average ground point density and still contain areas of several square meters without a single ground point. We made the same observation about scan patterns: an average hides where the points actually are.
Gaps in the canopy explain why tall forest reduces the number of ground points. They do not explain the Wytham Woods result, where the lowest vegetation caused the largest errors. For that, we need to look at the pulse along its direction of travel.
Why Low Vegetation Is Harder Than Tall Trees
A laser pulse also has a length. A pulse that lasts a few nanoseconds is more than a meter long in the air. When it hits two surfaces that are far apart, such as a treetop and the ground 20 meters below, the two echoes arrive at clearly different times and the sensor records them as two separate returns. When the two surfaces are close together, the echoes overlap and merge into one. The smallest vertical distance at which a sensor can still separate two echoes is called its multi-target resolution. Depending on the sensor, it ranges from a few decimeters to more than a meter, and some discrete-return systems also need a short recovery time after each detected echo.
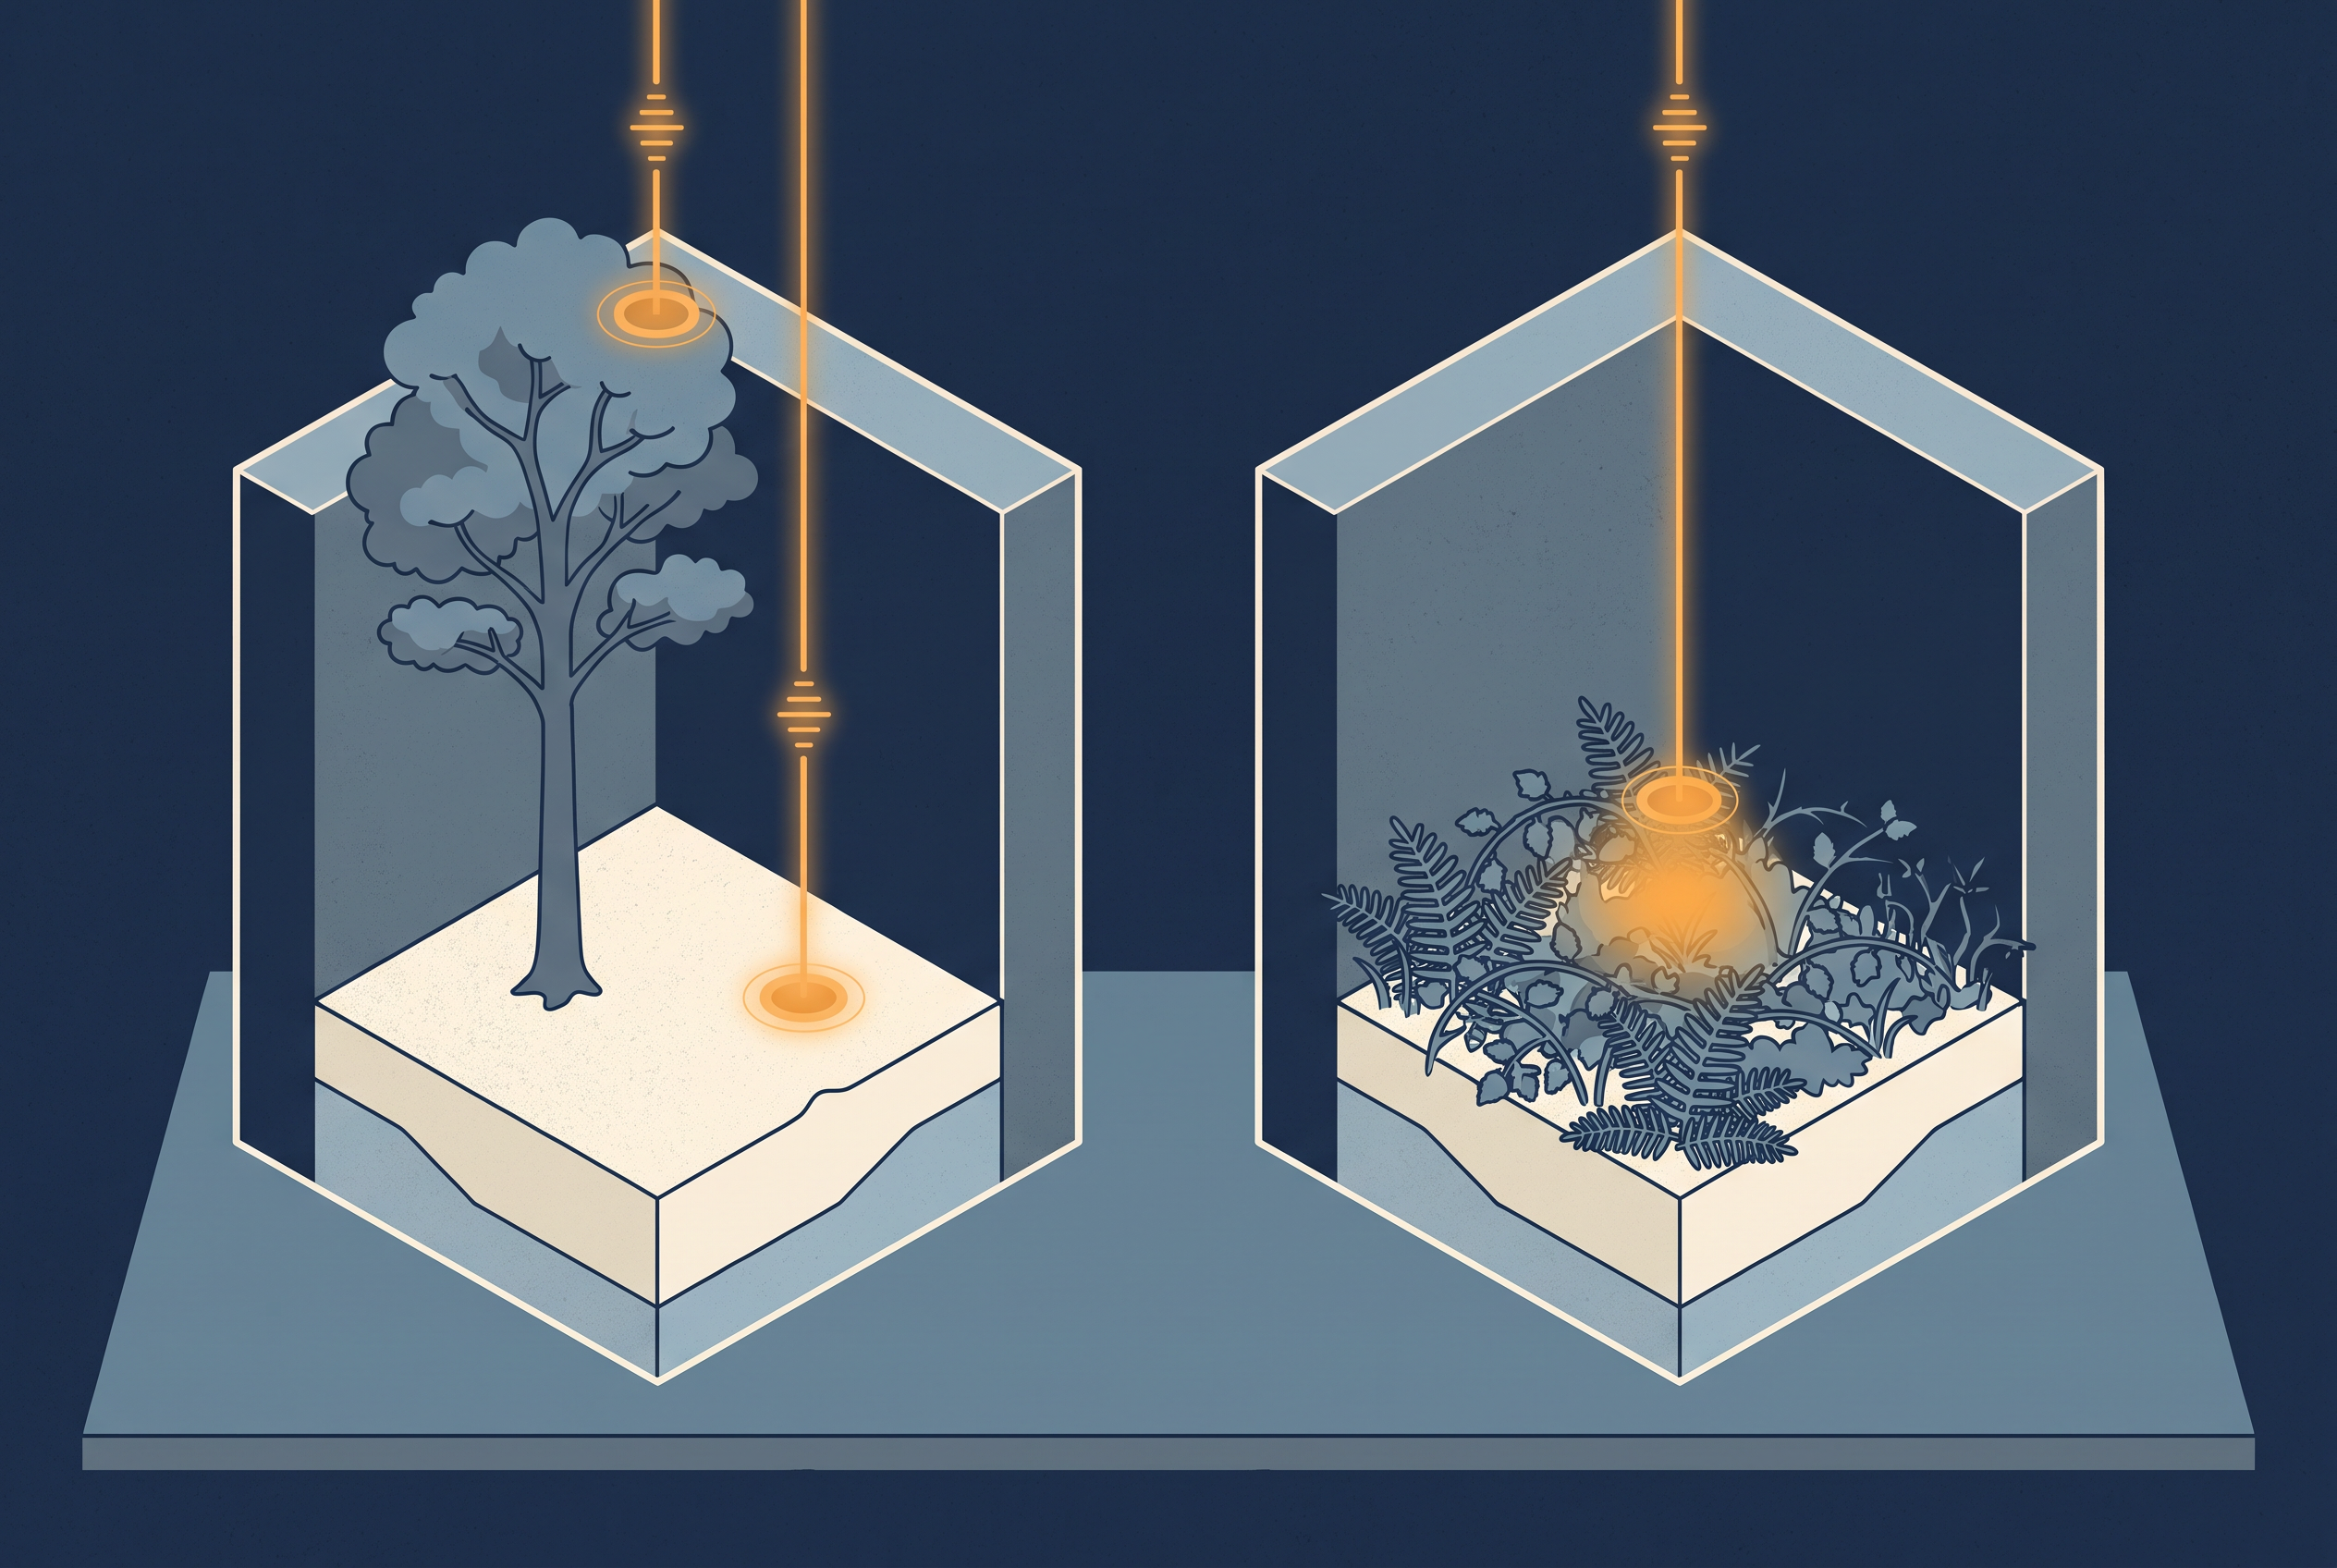
Under a tree, this does not matter much, because the canopy and the ground are far apart. Under a layer of ferns half a meter high, it matters a great deal. Some of the photons still pass through the ferns and come back from the soil, but the ferns reflect far more of the pulse, so the ground signal arrives right behind a much stronger peak. A discrete-return sensor reports that strong peak as the last return, and the weak contribution from the ground is treated as noise and discarded. What happens next depends on the ground filter. A simple classification accepts the last return as ground, because the point sits low, on a smooth surface, with no obvious outliers, and the terrain model is lifted by the height of the undergrowth. A more careful algorithm may recognize that the point belongs to the ferns and reject it, but then nothing is left to represent the ground at that location, and the result is a gap instead of a bias.
This is the important difference between the two problems. Tall, dense canopy produces gaps in the ground points, which you can see if you map the ground point density. Low vegetation produces a bias in points that look perfectly valid, or in gaps where a filter rejects them. Sensors that record the full waveform of the returning signal keep the whole distribution of the returning photons, so the weak ground contribution behind the fern peak can still be recovered in post-processing. With discrete returns, that information is gone as soon as the sensor decides what counts as an echo.
Further reading
Assessment of Errors Caused by Forest Vegetation Structure in Airborne LiDAR-Derived DTMs | Jake Simpson, Thomas Smith, and Martin Wooster, Remote Sensing
A field study that compares leaf-on and leaf-off terrain models across six vegetation structure classes and shows that low undergrowth, not canopy height, drives the largest errors.
Survey Choices That Change Ground Coverage
Some of the factors that decide ground coverage are fixed by the landscape. Many others are decided when the survey is planned.
The first is season. In deciduous forest, flying without leaves opens the canopy and, as Wytham Woods showed, can reduce terrain errors by a factor of three or four. The U.S. Geological Survey’s Lidar Base Specification states that leaf-off conditions are preferred and that the ground must be free of snow. In practice the leaf-off window is short, it competes with snow cover in northern countries, and it does nothing for evergreen forest or for undergrowth that stays green.
The second is scan angle. A pulse sent straight down crosses the canopy along its shortest path. A pulse sent at a steep angle crosses more vegetation before it reaches the ground and is more likely to be blocked. A narrower field of view therefore tends to improve ground coverage in forest, at the cost of more flight lines. At the same time, overlap between flight lines helps in a different way. Pulses from two directions find different gaps in the same canopy, so a ground patch hidden from one line may be visible from the next.
The third is the pulse itself. A higher pulse repetition frequency sends more pulses into the canopy, but with less energy in each one, and a weak pulse may not have enough energy left to produce a detectable ground echo after passing through several layers of leaves. Footprint size works in two directions. A small footprint can pass through small gaps, while a larger one spreads its energy over more gaps but returns weaker echoes. Flying altitude changes both the footprint and the energy that arrives at the ground.
Drone LiDAR adds its own twist. Drones fly low and slowly, so they can deliver very high point densities, but many compact sensors record fewer returns per pulse and use less powerful lasers than airborne survey systems. Density alone does not compensate for this. In a comparison published by the New Zealand forestry consultancy Interpine in late 2025, two generations of the same drone sensor were flown over plantation forest. The older sensor left gaps in the ground points, so the terrain model spanned them with flat, angular facets, while the newer one produced a continuous surface under the same canopy. The difference came from how the sensor detects and separates echoes, not from how many points it collected.
Whichever choices are made, the result eventually reaches the same step: turning the ground points into a surface.
What Sparse Ground Does to a Terrain Model
A terrain model is interpolated from the ground points, and the interpolation has to fill every gap, whatever its size. Where ground points are dense, the choice of method hardly matters. Where they are sparse, the method decides what the terrain looks like. A triangulated surface connects the ground points on either side of a gap with flat triangles. Like a tent sheet pulled over poles, it spans the empty area in straight planes and sharp ridges instead of following the real terrain, an effect often called tenting. Smoother methods produce surfaces that look more natural but are just as invented. Either way, small features such as a ditch, a scarp, or a forest road can disappear, a problem we described for landslide mapping under forest.
Gaps at least leave evidence. A map of ground point density, or of the distance from each terrain cell to the nearest ground point, shows exactly where the model is guessing. The bias from low vegetation leaves no such evidence. The ground points are there, they are dense, and they are wrong by a few decimeters. The only reliable way to find this kind of error is to compare the terrain model with independent checkpoints measured on the ground in the vegetation types that matter.
This is where accuracy reporting has recently changed. The current edition of the ASPRS Positional Accuracy Standards no longer treats vertical accuracy in vegetated areas as a pass or fail criterion, but as information to be reported. The reasoning is fair: the accuracy under vegetation depends on conditions that the data provider cannot fully control. The consequence is that a dataset can meet its specification while the terrain under the ferns is still half a meter too high, and it becomes the user’s job to know that.
Further reading
- Analysis of LiDAR DJI L2 vs L3 LiDAR Sensors | Interpine
A side-by-side look at ground detection and terrain models from two drone sensors over the same plantation forest. - The ASPRS Positional Accuracy Standards, Edition 2 | LIDAR Magazine
An overview of what changed in the standards, including how accuracy in vegetated areas is now reported.
Questions to Ask About Ground Coverage
If ground under vegetation matters for your project, a few questions go further than the point density on the specification sheet. What ground point density was achieved in the forested parts of the project, and is there a map of it rather than an average? When was the survey flown, and were deciduous areas leaf-off? How many returns per pulse does the sensor record, and how close can two echoes be before it merges them? How were low vegetation and ground separated in dense undergrowth? And were checkpoints measured under vegetation, or only on open ground where every survey looks good?
These questions matter because the ground under vegetation is where many of the most valuable applications of LiDAR live. Landslide scars, archaeological remains, drainage lines in forest, and the terrain reference for canopy height and biomass are all measured against it. It is also the part of the survey that a specification sheet describes least well. As drone LiDAR brings high point densities to more projects, the useful question shifts from how many points a survey collects to how many of them reach the ground, and whether the ground they reach is really the ground.
Further reading
- Lidar Base Specification: Collection Requirements | U.S. Geological Survey
The collection rules behind the U.S. national program, including leaf-off and snow conditions and minimum pulse density. - Airborne Lidar: A Tutorial for 2025 | Gottfried Mandlburger, LIDAR Magazine
A clear introduction to multiple returns and how they let UAV and airborne LiDAR see through vegetation.