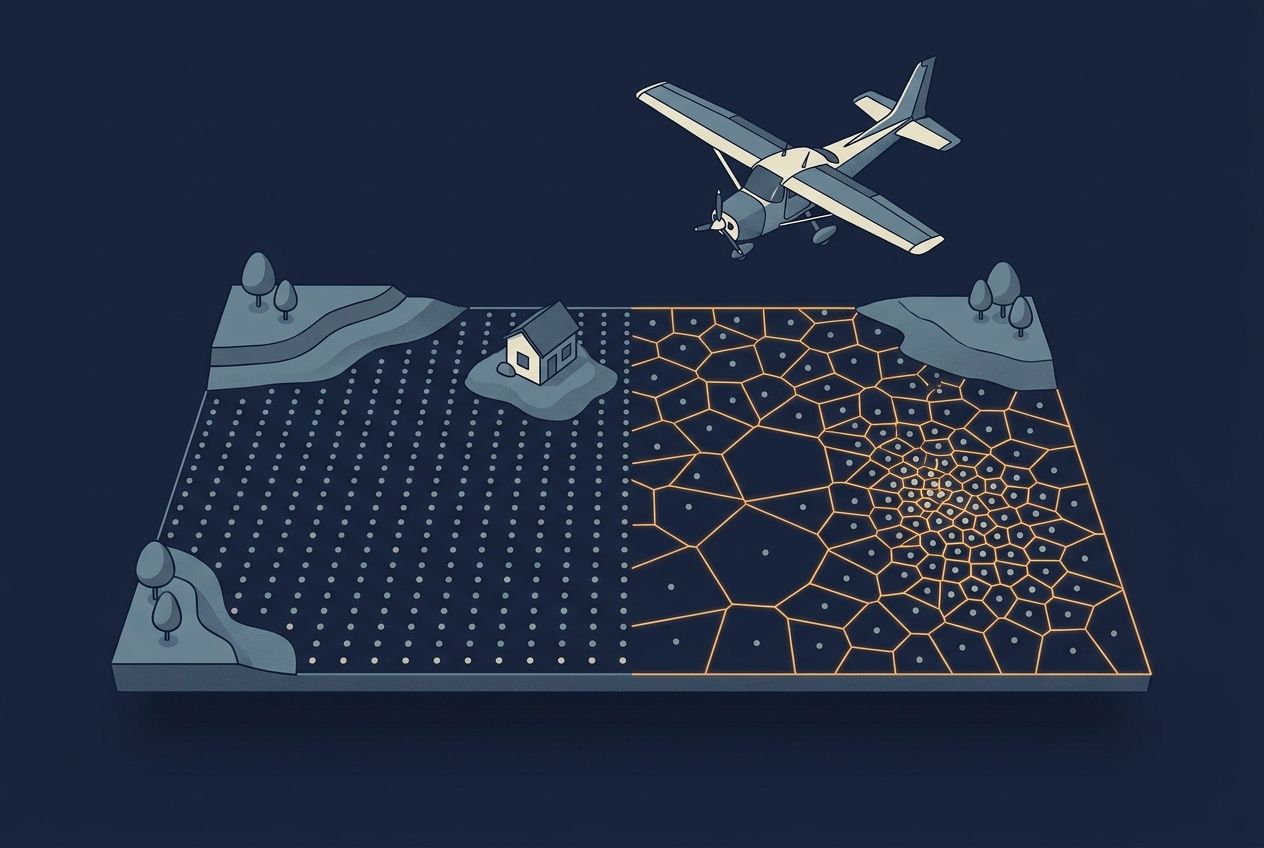
Imagine a point cloud with perfectly even spacing, laid out on a regular grid at exactly two points per square meter. Count the points in one-meter cells, as many QC tools do, and the result is a patchwork. Some cells hold one point, some hold two, and some hold four. Now run the same count on a dataset with real gaps in it, and the project average can still land above the contract minimum. The even dataset looks flawed, the uneven one looks fine, and the counting method is the reason for both results.
Density is easy to state and surprisingly hard to measure. The American Society for Photogrammetry and Remote Sensing (ASPRS) took on that problem in its Guidelines on Quantifying Horizontal Sampling Density of Aerial Lidar Point Cloud Data, which its Board of Directors adopted in February 2025. The guidelines review the methods in common use, compare their trade-offs, and recommend Voronoi polygons as the preferred way to test density. This article walks through those methods, explains why a document from ASPRS carries weight in contracts, and shows how the recommendation can change the way you plan, test, and deliver LiDAR data.
What Point Density Means in a Specification
Point density is the number of points per unit of area, usually points per square meter. Point spacing is its companion measure, and the ASPRS guidelines define it as the inverse of the square root of density, so 4 points per square meter corresponds to a spacing of 0.5 meters. Specifications lean on density because it fits into a single line of a contract. The USGS Lidar Base Specification, for example, asks for an aggregate nominal pulse density of at least 2 pulses per square meter at quality level 2 and at least 8 at quality level 1. The relationship between the two terms is covered in more detail in Point Density and Point Spacing.
That single line hides several decisions. ASPRS asks that every density statement carry two qualifiers. The first is whether the value is a design density or a tested density. Design density is predicted before the flight from aircraft speed, pulse repetition frequency, scan angle range, scan frequency, and distance to the target. Tested density is what an analysis of the delivered points actually returns. The second qualifier is the point type, which names the points that were counted: first returns, last returns, all returns, or only points classified as ground. A statement such as “2 points per square meter” therefore says little until it also names the point type, the statistic used, and the area over which it was calculated.
A contract is decided by the tested value, so the way it is measured becomes part of the specification whether or not anyone wrote it down. Two reasonable methods applied to the same delivery can disagree about whether it passes. That disagreement is what the ASPRS guidelines set out to resolve.
Why the ASPRS Standard Matters
ASPRS is the organization behind two documents that sit underneath most airborne LiDAR contracts in the United States. One is the LAS file format specification, which defines how points are stored (see A Closer Look at LAS Formats). The other is the Positional Accuracy Standards for Digital Geospatial Data, which defines how vertical and horizontal accuracy are tested and reported. The USGS Lidar Base Specification, which sets requirements for collections under the 3D Elevation Program, builds on both.
The influence continues further down the chain. USGS describes its specification as the foundation that numerous state, county, and foreign country LiDAR specifications adopted for their own use, so a measurement rule written into an ASPRS document can reach contracts well beyond federal programs. I have encountered this myself while replying to RFPs for LiDAR projects in Africa. The RFPs referred to the USGS Lidar Base Specification throughout to clarify every detail, with no apparent reason for the choice other than that the requirements are well documented.
There is a limit to that influence. An ASPRS guideline is a recommendation. It binds you only when a client writes it into a contract or an agency adopts it in its own specification. For now, that makes the guideline optional, but it is worth understanding before a client asks for it, starting with how the common methods to measure density compare.
Common Ways to Measure Density
The guidelines compare several methods. Six of them have been in everyday use for years, and they fall into three groups:
- The first group summarizes an area with one number: a representative sample, a per-swath calculation, or an aggregate over the whole project.
- The second group builds a raster and counts points in its cells, either across the full swath or only its center, with or without a pass or fail rating per cell.
- The third group measures the area each point represents, which is where the newest method sits.
The table summarizes the six established ones.
| Method | How it works | Main limitation |
|---|---|---|
| Representative sample | Count the points inside one or a few small areas of interest and divide by their area. | Fast, but overlap, crosslines, and position in the scan can inflate the result, and it cannot find problem areas across a project. |
| Per swath | Divide the points in each flight line by the area of that swath. | Compares well with the planned density and is not inflated by overlap, but it misses local changes such as a shift in aircraft speed or pitch. |
| Aggregate | Divide all points inside a boundary by the area of that boundary. | Reports a single value that overlap, crosslines, and patches inflate, and it cannot show where density fails. |
| Point in cell | Count the points in each cell of a raster and compare the counts with the requirement. | Produces a map, but the result changes with cell size and suffers from aliasing. |
| Sweet spot of the swath | Run the point in cell count on only the central 20 percent of each swath. | Avoids overlap and swath-edge effects, but hides lower density elsewhere and keeps the cell-size problems. |
| Binary raster | Mark each cell pass or fail against the required count and report the percentages. | Easy to report, but there are no established thresholds, and cell size changes the result. |
Each of these answers a slightly different question, and the guidelines are careful to separate four of them. What is the density of the dataset? How does it vary across the project area? Does it meet the minimum, and if not, where does it fail? Can it be used for the intended application?
A single average answers the first. A map answers the second. Only a test that is tied to a threshold and shows where it fails answers the third, and the fourth depends on what you plan to build.
The guidelines also place density testing after the checks for spatial distribution and data voids, so that a dataset with obvious holes is not rated on density first.
Where Counting Points in Cells Goes Wrong
Of the established methods, point in cell deserves a closer look. It is the most widespread way to turn density into a map, which fixes the main weakness of the aggregate: it shows where the data is sparse. It also carries a flaw that is easy to miss. The answer depends on the cell size chosen, and points that fall just outside a cell are not credited to it.
The deeper problem is aliasing, which the guidelines define as the distortion that appears when evenly spaced samples, here the raster cells, are used to measure randomly spaced points. ASPRS demonstrates it with a synthetic dataset of perfectly even points, where counting in one-meter cells produces cells with 1, 2, and 4 points. The figure below uses randomly spaced points instead, which is closer to real data. Both panels show the same points, and the counts in the left panel range from 0 to 4 although the average is 2 points per square meter.
The perfectly even case is extreme, yet real data shows the same distortion in less regular patterns. ASPRS points out that these distortions are strongest near the minimum required density, which is also where LiDAR is cheapest to collect. A provider who plans close to the specification, which is a perfectly rational thing to do, is exactly the one whose pass or fail result depends most on an arbitrary choice of cell size.
Further reading
Guidelines on Quantifying Horizontal Sampling Density of Aerial Lidar Point Cloud Data | ASPRS
The full document, led by Matt Bethel, with each density method applied to the same dataset so the differences can be compared directly.
The Newest Approach: Voronoi Polygons
The guidelines rate every method against a short list of requirements. Among them are project-wide measurement, results that overlap and crosslines cannot inflate, independence from the scanner type, and the ability to locate failures anywhere in the project instead of relying on samples that can miss them. Only the Voronoi method meets all of them. That is the reason ASPRS recommends it, and it counts as the newest approach mainly in the sense of being the one now preferred.
A Voronoi polygon is the region around a point that lies closer to that point than to any other point in the dataset. Building one for every point divides the ground into cells that fit together without gaps, and the area of each cell tells you how much ground that point stands in for. The density at a point is simply one divided by the area of its cell. Where points are packed tightly the cells are small and the density is high. Next to a gap the cells are large and the density is low. In the right-hand panel of the figure, the large red cells in the upper left mark a real gap, and the small blue cells right of center mark a cluster. Each cell carries its own density value, so the result does not depend on where a grid happens to fall. For the perfectly even example, every Voronoi cell would have an area of 0.5 square meters, and the method would report 2 points per square meter everywhere, which is the correct answer.
The guidelines turn this idea into a testing procedure. A polygon is built for each last return point, and each polygon area is converted to a density. The densities are summarized in a frequency distribution chart, with a default upper cutoff of four times the design density, and they are rasterized at half the nominal point spacing to produce a thematic density map. The pass or fail decision uses a much coarser raster, with cells 100 times the nominal point spacing wide, which is about 70 meters for a project designed at 2 points per square meter. Each coarse cell takes the most common density value found inside it and passes if that value meets the design density. Water bodies and cells that are not fully covered by data are set to no data. ASPRS names 90 percent or more passing cells as an ideal guideline for an acceptable block of data.
The coarse cell is a deliberate choice. Using the typical density within a large cell keeps a single building shadow or a patch under a tree from failing an otherwise sound area, so the test responds to broad zones of low density and not to every small gap. ASPRS also lists overlap, crosslines, patches, and scanner type among the factors that do not bias the result, and it shows that changing the test cell size barely moves the pass percentages. That stability is exactly what the counting methods lack.
The method has costs. Constructing Voronoi polygons takes more computation than counting points, and processing time grows faster than the number of points. The guidelines suggest splitting the data into virtual tiles, processing in parallel, or measuring from a subsample of points. Software support is also still limited, which the guidelines list as a disadvantage and which is why they ask vendors of LiDAR quality assessment software to offer a Voronoi option. The idea itself has been in the research literature for years, for example in the work of Rupnik, Mongus, and Žalik on evaluating density from the Voronoi regions of LiDAR points.
Further reading
- Point Density Evaluation of Airborne LiDAR Datasets | Rupnik, Mongus, and Žalik, Journal of Universal Computer Science
An academic description of building a Voronoi diagram on LiDAR points and reading the density of each point from its cell area. - Validation of the Geometric Accuracy of Airborne Light Detection and Ranging Data for Eastern Iowa, 2019 | USGS
A USGS report that applies the Voronoi method to sample tiles and summarizes the resulting density statistics against the 2 points per square meter requirement.
What Changes for Data Delivery
The first change is in the report. The guidelines expect a frequency distribution chart, statistics that describe the spread of density values, a thematic density raster, and a pass or fail raster, each stating the point type it is based on. A single average in a QC summary no longer fits that description. If you deliver data, expect clients who know the guidelines to ask for the maps, and expect them to open the pass or fail raster and look at where the failing cells sit.
The second change is in flight planning. ASPRS treats density as a distribution and warns that planning for an average equal to the requirement leaves roughly half of the data below it. The guidelines therefore recommend over-planning the design density so that most of the distribution sits above the requirement. That margin has to come from somewhere, and the levers are the ones that set density in the first place: pulse repetition frequency, scan pattern, flying speed, and altitude. More margin means slower flying or more flight lines, which means cost, so it belongs in the conversation when the survey is scoped and not when the first QC report arrives.
Projects that reach their density through more than 50 percent overlap, crosslines, or multiple sensors are covered as well. The guidelines require a method that works for those acquisition designs and that cannot be inflated by overlap which exists only for coverage. For a provider, that removes one way of passing on paper while leaving sparse zones in the data.
The third change is in QC tooling. If your pipeline reports density by counting points per cell, find out whether your software can produce a Voronoi report or whether you need an additional tool or script, and allow processing time for it in the schedule. The work is not entirely overhead. The guidelines note that Voronoi polygons and their dual, the Delaunay triangulation, are useful products in their own right, and that many users already request them together with the point cloud.
The last change is in the contract itself. A requirement of the form “minimum 2 points per square meter” leaves the method open, and the guidelines show how far apart the answers can be. Agreeing on the point type, the measurement method, and the pass threshold in advance protects both sides. The 90 percent figure is described as an ideal guideline and not as a rule, so it is a starting point for that conversation and not a number to assume. The same applies if you are the data buyer. The pass or fail raster shows where a shortfall sits, which is the information you need to decide whether supplemental flying is justified.
What Density Still Does Not Tell You
A better density measurement answers a narrower question than it may seem to. Density describes how often the ground was sampled. It does not describe what the samples found. The guidelines say so themselves. The first edition leaves out vertical density, which matters on building walls and trees, and it does not filter for overlapping laser footprints, where heavily overlapping footprints may repeat the same measurement and add little new information.
The same limit shows up under vegetation. A survey can meet its density target on all returns and still place few pulses on the ground below a dense canopy, which is why the guidelines allow density to be tested on ground-classified points alone. Whether that ground density is enough then depends on what you want to build from it, a decision that sits one step beyond any density test. The useful habit, whichever method a contract names, is to ask for every density figure which points were counted, over what area, and for what use. That question applies to every dataset you evaluate, not only those delivered under a United States specification, and it leads directly to the next one: how much density your application needs in the first place.